


Next: The Group of Rigid Up: Rotations as a Lie Previous: Logarithmic Map
In iterative algorithms, it is not convenient to update a rotation matrix directly using
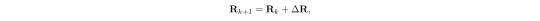 |
(A.38) |
because the result might no longer belong to  .
Instead, an infinitesimal perturbation is used:
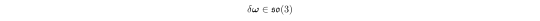 |
(A.39) |
and the solution is updated according to
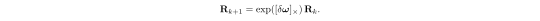 |
(A.40) |
This approach automatically preserves the orthonormality of the matrix.
This formulation is widely used in extended Kalman filters, pose estimation, visual odometry, and bundle adjustment.