


Next: Incremental Updates Up: Rotations as a Lie Previous: Exponential Map
The inverse operation is the logarithmic map
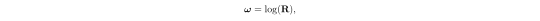 |
(A.36) |
which makes it possible to convert a rotation into an axis-angle vector.
The logarithmic map is frequently used to define errors between
rotations. Given two orientations  and
 , the rotational
error can be expressed as
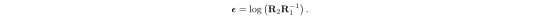 |
(A.37) |
The norm of
 represents the minimum angle required
to align the two orientations.