


Next: Nomenclature Up: Rotations as a Lie Previous: Incremental Updates
Three-dimensional rigid transformations belong to the group
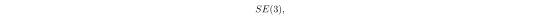 |
(A.41) |
defined as
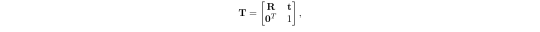 |
(A.42) |
where
 and
 .
While  describes rotations exclusively,
 represents
rotations and translations simultaneously.
The poses of cameras, sensors, and vehicles are generally
represented by elements of .
Pose optimization in calibration, visual odometry, SLAM, and bundle adjustment problems is often formulated directly in the tangent space associated with this group.