


Next: Lie Algebra Up: Rotations as a Lie Previous: Rotations as a Lie
The set of three-dimensional rotation matrices is denoted by
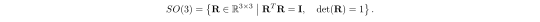 |
(A.29) |
The composition operation is matrix multiplication.
The symbol  derives from Special Orthogonal Group:
 ;
 ;
The set does not constitute a vector space. Indeed, the sum of
two rotation matrices is not generally a rotation.
Rotations instead belong to a differentiable manifold and can be studied locally through their tangent space.