


Next: RANSAC Up: Regression and Optimization Methods Previous: Black-Rangarajan Duality
|
Let
 be a continuous manifold in
 whose parameters
 are to be estimated.
To recover these parameters and completely define the function, a set of coordinates
 belonging to the locus of the function is available; these coordinates may be noisy and, above all, may contain outliers.
The Hough Transform (Hough Transform) is a technique that makes it possible to group a “highly probable” set of points satisfying certain parametric constraints (PIK92).
For each possible point
 in parameter space, it is possible to assign a vote
 of the form
 satisfying the constraint expressed by
 . The parameter
that maximizes this vote is the statistically most probable solution to the problem.
Now let the function
 be a likelihood measure between the pair
 and the constraint expressed by
.
The function
 is normally binary, but can readily represent a probability in the general case.
Using the function , the Hough transform
can be constructed incrementally through
For particular constraints, this approach can be simplified further to reduce computational and memory costs.
Let
 therefore be bounded, quantizable parameters to be estimated, and let
 and
 be a function and a parameter such that the function
can be written as
can be expressed as in equation (4.126), the discrete Hough transform can be used to estimate the parameters
 representing the most “probable” model among all the supplied points .
For each element , the parameters
 can be varied over their range, and the values of returned by function (4.126) can be inserted into the accumulator image
.
This makes it possible to generate an n-dimensional probability map using observations affected by noise and potentially containing outliers.
Similarly, the Hough method makes it possible to estimate a model in the presence of a mixture of models with different parameters.
The performance of the Hough method improves as the number of constraints increases, dynamically restricting, for example, the range of the parameters associated with sample .
The Hough algorithm can be viewed as a degenerate form of template matching.
The use of Hough is generally most interesting when the model has only two parameters, since it can then be easily plotted on a two-dimensional map.
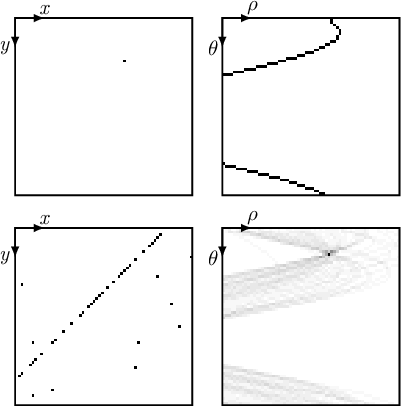
A very common example of the Hough transform is the case in which (the model) is a line, expressed in polar form as in equation (1.82), where the parameters to be determined are  and
 :
it is clear that, for every pair of points
 and for every possible quantized and bounded angle (since the angle is a bounded parameter), there is one and only one satisfying equation (1.82).
It is therefore possible to create map
 in which, for every point
 and every
 , the element associated with
 is incremented in the accumulator map; this relationship satisfies equation (1.82) for the line expressed in polar coordinates.
Paolo medici


