


Next: 2D Gaussian Splatting Up: Reconstruction, Representation, and Rendering Previous: Neural Representation and Radiance
The idea behind 3D Gaussian Splatting is to represent the scene using a set of three-dimensional Gaussian primitives.
3D Gaussians are based on the three-dimensional extension of one-dimensional Gaussians.
Three-dimensional Gaussians are defined by a covariance matrix  (in world coordinates) and centered at the point (mean)
 :
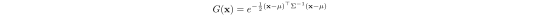 |
(10.119) |
Before it can be rendered, this Gaussian must first be transformed into the camera coordinate system and then projected onto the image plane. Since perspective projection is nonlinear, a local approximation is introduced by linearizing the projection using its Jacobian  . The three-dimensional covariance is thus projected into a two-dimensional covariance
 :
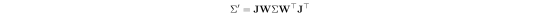 |
(10.120) |
 represents only the rotational component of the camera-to-world transformation. Translation does not directly affect the covariance, but it determines the scene point
 in camera coordinates at which the Jacobian of the perspective projection is evaluated.
For example, in the case of a pinhole camera projection:
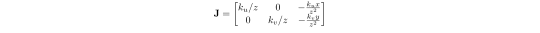 |
(10.121) |
is therefore a  (ZPvBG01) matrix describing the covariance of the Gaussian ellipse projected onto the image plane.
In (KKLD23), a further step is taken: because parameterizing a covariance matrix (positive semidefinite) is difficult, one starts from the fact that the matrix defines a family of level ellipsoids. It is therefore possible to use a minimal parameterization based on the dimensions and orientation of this ellipsoid, rather than treating all the matrix elements separately.
The idea is to use a scale matrix  (3 DOF) and a rotation matrix
 (another 3 DOF, but normally represented by a quaternion; see Section A.3):
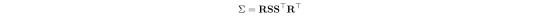 |
(10.122) |
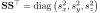 .
Finally, each Gaussian may be associated with an RGB color or with a direction-dependent radiance representation using spherical harmonics (Spherical Harmonics, SH), in addition to the opacity parameter  , analogous to that used in NeRF.
In practice, the Gaussians are rendered in depth order, from nearest to farthest, progressively compositing their radiometric contributions10.8.