


Next: Implicit 3D Modeling: RBFs Up: Reconstruction, Representation, and Rendering Previous: 3D Gaussian Splatting
Instead of representing the scene using three-dimensional volumetric Gaussians, it is possible to use Gaussian primitives defined on local two-dimensional elements. This formulation, known as 2D Gaussian Splatting, predates modern techniques based on three-dimensional Gaussians and represents a different trade-off between geometric modeling and computational cost.
2D Gaussians are represented by a center point  , two unit tangent vectors (
 ,
 ), and a scale factor
 that controls the two-dimensional variance of the Gaussian.
The orientation of the 2D Gaussian can be organized into a rotation matrix  of rotation
 (parameterizable as a standard 3D rotation), with
 defined and the scale factors arranged in a diagonal matrix
 .
The plane parameterization can be written as an affine transformation of the local coordinates  :
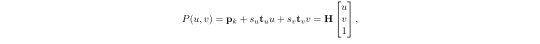 |
(10.123) |
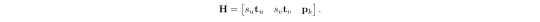 |
(10.124) |
 is the matrix of the affine embedding.
Each point in plane coordinates is clearly associated with a Gaussian defined by the equation
 .