Next: Rotations as a Lie Up: Rotation Matrices Previous: Infinitesimal Rotations
Son: Well, Papa, can you multiply triplets?
Father: No [sadly shaking his head], I can only add and subtract them.
(William Rowan Hamilton, Conversation with his sons (1843))
Quaternions are an attempt to extend complex numbers to a higher-dimensional space. This formulation was first proposed by Sir William Rowan Hamilton.
They are represented by a vector of
 in the form
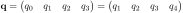 .
Quaternions have different properties from ordinary four-dimensional vectors (as are, for example, homogeneous coordinates).
The quaternion (A.18) can be viewed as consisting of a vector part
 and a scalar part
 :
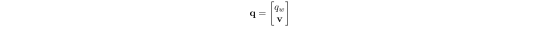 |
(A.19) |
is defined as the scalar part (or real component), while  are the vector (or imaginary) components.
A quaternion with only a scalar part is called real, while a quaternion with only a vector part is called pure.
The product of quaternions, for example, is not commutative (but is nevertheless associative).
It is possible to create an augmented vector (augmented vector) from a vector
 in quaternion space as:
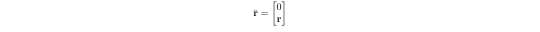 |
(A.20) |
The complex conjugate of a quaternion
 is
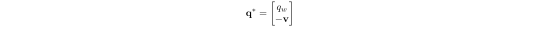 |
(A.21) |
The norm
 is
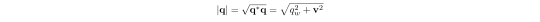 |
(A.22) |
 is called a unit quaternion.
The inverse of a unit quaternion is its complex conjugate
 .
The most important property of a quaternion is that it represents a rotation in  .
A rotation
 , expressed in axis-angle representation, can be written as a quaternion
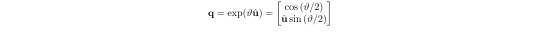 |
(A.23) |
 is an angle of rotation and
 is a three-dimensional unit vector.
In this case, it is a unit quaternion and represents a rotation through an angle about the axis
.
Note that a rotation of
 with respect to
 yields the same quaternion as a rotation of about
, resolving the singularity of the axis-angle representation.
Similarly, it is possible to define the “logarithm” of a quaternion:
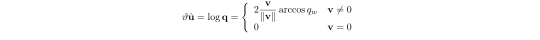 |
(A.24) |
Rotations are represented by unit-length quaternions
 .
It is possible to rotate a point directly using quaternions
 , or a unit quaternion can be converted into a rotation matrix (directional cosine matrix):
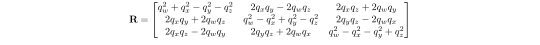 |
(A.25) |
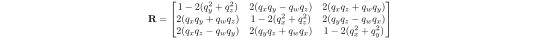 |
(A.26) |
 .
It should be noted that  and
 represent the same rotation matrix
 : the space of three-dimensional rotations
 is not represented bijectively by
 , but by with antipodal identification.
Conversely, the quaternion can be obtained from the rotation matrix, for example, through
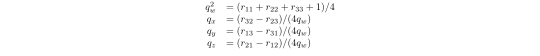 |
(A.27) |
Finally, the product of two quaternions represents the composition of rotations:
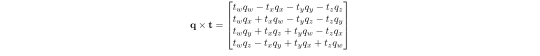 |
(A.28) |
Paolo medici