


Next: Quaternions Up: Axis-Angle Parameterization Previous: Axis-Angle Parameterization
The compact definition
 , together with the Rodrigues formula, makes it possible to express infinitesimal rotations in a very simple-to-compute form.
Indeed, if  is taken to be infinitesimal, formula (A.13) can be approximated as
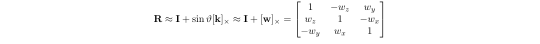 |
(A.17) |
 associated with the rotation group A.4.