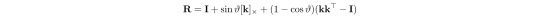Next: Infinitesimal Rotations Up: Rotation Matrices Previous: Euler Angles
Every rotation is equivalent to a rotation about an axis (of rotation) by a certain angular amount. The formulation of a Rodrigues rotation, or Axis-Angle Parameterization, is based on this premise. The Rodrigues formulation attempts to solve the singularity problems intrinsic to the Tait-Bryan and Euler formulations (different combinations of values represent the same rotation matrix), while also providing a geometric and concise formulation of rotation.
The rotation formula proposed by Rodrigues consists of a unit vector  and an angle
 , which make it possible to represent a rotation of points in space by an angle about the axis defined by the vector , with positive direction according to the right-hand rule.
It is possible to convert an axis and an angle into a rotation matrix through a compact equation proposed by Rodrigues:
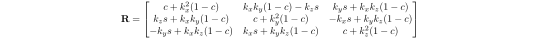 |
(A.14) |
 and
 .
When
 , that is, in the absence of rotation, the matrix reduces to the identity.
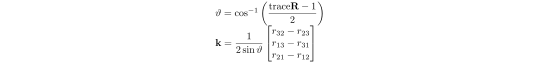
The inverse formulation is also extremely compact and is given by:
 |
(A.15) |
Since and are in fact 4 parameters, a generic vector
 is usually used to represent a rotation in the Rodrigues formulation, and the substitutions
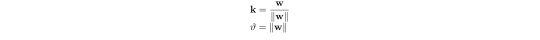 |
(A.16) |
 to
 .