


Next: Exponential Map Up: Rotations as a Lie Previous: The Rotation Group
The tangent space of  at the identity is denoted by
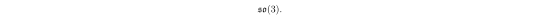 |
(A.30) |
The elements of
 are skew-symmetric matrices of the form
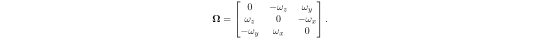 |
(A.31) |
Introducing the vector
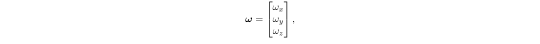 |
(A.32) |
it is possible to write, in compact form,
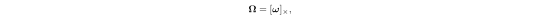 |
(A.33) |
where
 represents the matrix associated with the cross product.
It should be noted that the parameterization by infinitesimal rotations introduced
in the preceding sections coincides exactly with an element
of the Lie algebra
.