


Next: Implicit 3D Modeling: RBFs Up: Reconstruction, Representation, and Rendering Previous: 3D Gaussian Splatting
2D Gaussian Splatting can be viewed as a simpler alternative to 3D Gaussians and, historically, had already been introduced earlier.
2D Gaussians are represented by a central point  , two unit tangent vectors (
 ,
 ), and a scale factor
 that controls the Gaussian's variance in two dimensions.
The orientation of the 2D Gaussian can be organized in a rotation matrix 
 , parameterizable as a standard 3D rotation, by defining
 and the scale factors in a diagonal matrix
 .
The plane parameterization can be written as an affine transformation of the local coordinates  :
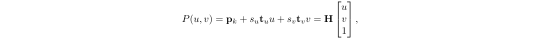 |
(10.120) |
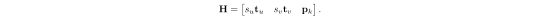 |
(10.121) |
 is the affine embedding matrix.
Each point in plane coordinates is clearly associated with a Gaussian defined by the equation
 .